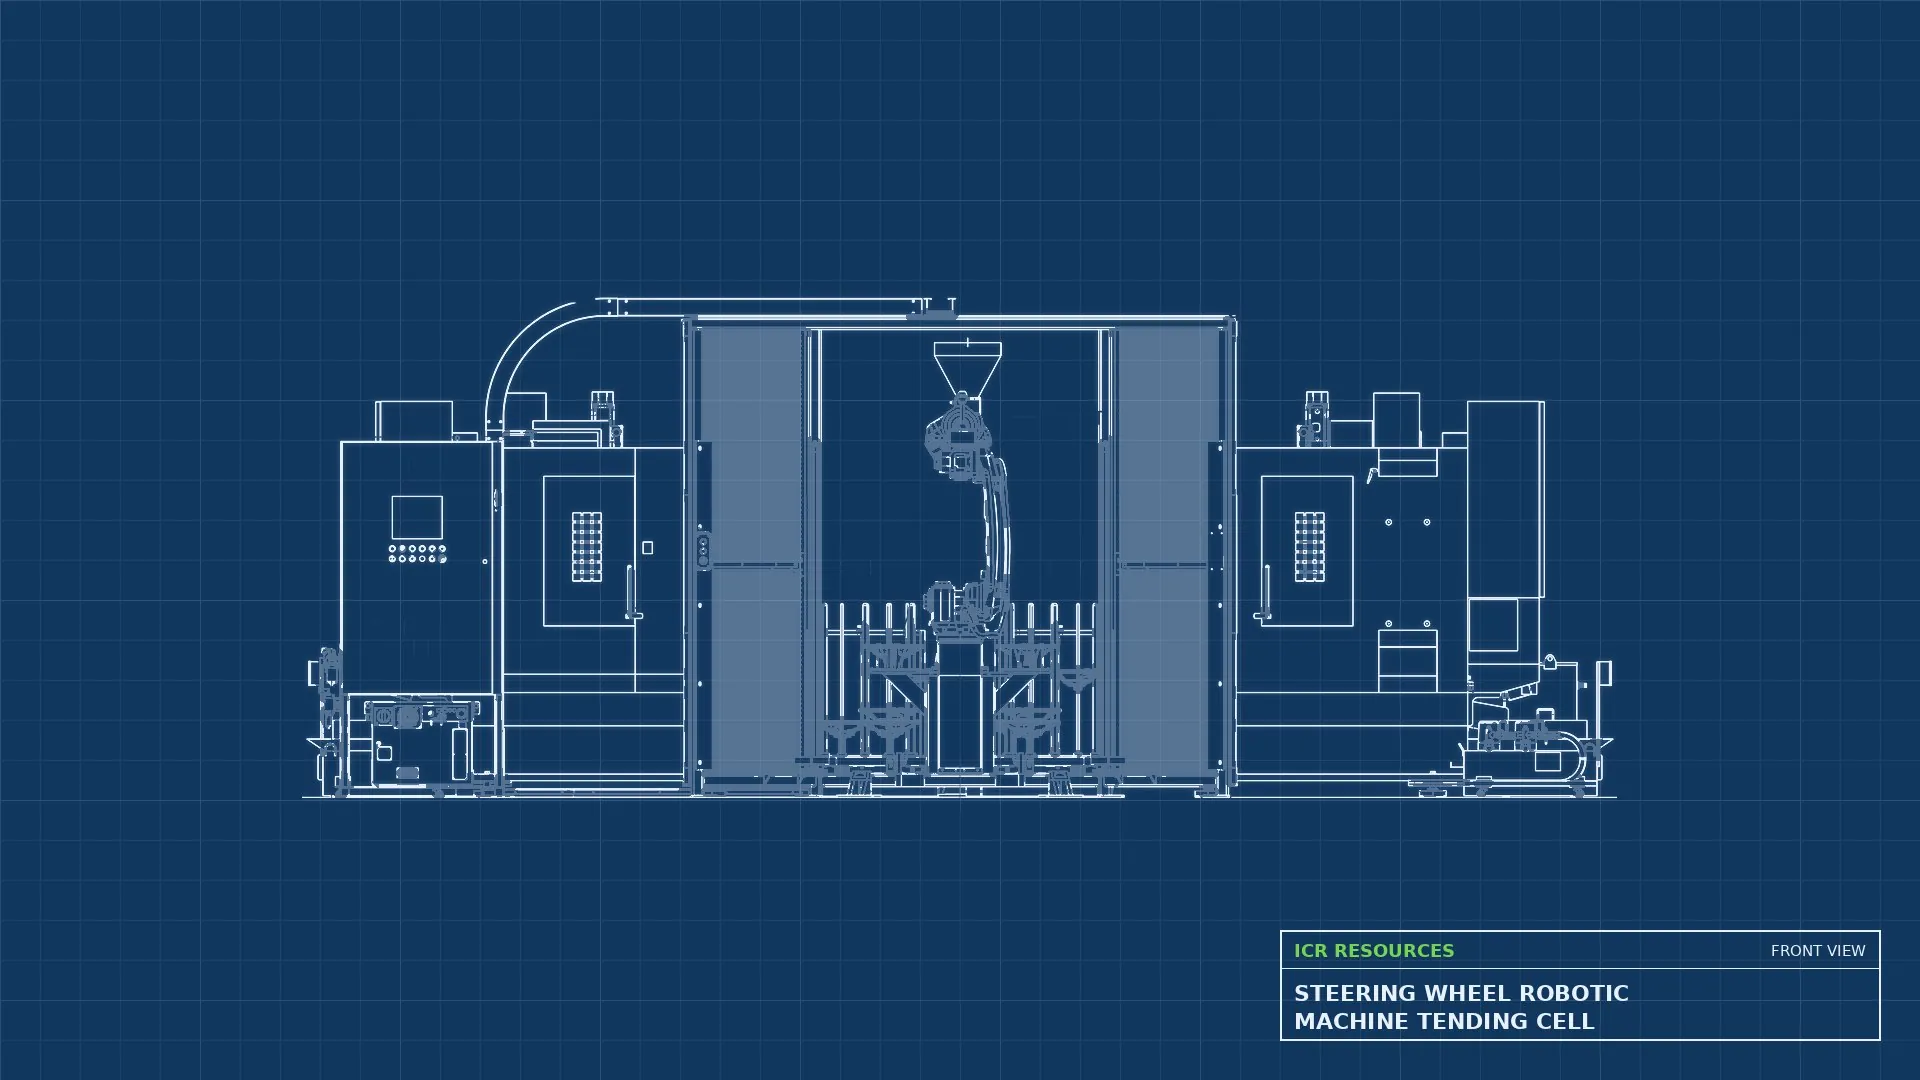
The customer needed to automate loading of two CNC machines with steering wheels that arrived randomly stacked on carts. A single robot had to locate and pick each part, manage two incoming and two outgoing carts, and keep both machines running without operator intervention.
Key Requirements
Cycle time under 60 seconds
Over 98% system efficiency
One robot servicing two CNC machines
Two incoming and two outgoing carts
The ICR Solution
ICR designed a robot cell around a FANUC robot (R-30iB controller) with 3D vision to locate and pick randomly stacked steering wheels. Because the CNC fixtures required precise part orientation, ICR added an intermediate part hotel where the robot re-grips each wheel before loading. An Omron PLC and HMI control the cell, and Keyence safety light curtains safeguard the operator areas.
Equipment & Technology
FANUC robot, R-30iB controller
3D vision system
Intermediate part hotel (re-grip station)
Omron PLC
Omron HMI
Keyence safety light curtains
Scope of Work
Results
A single FANUC robot now loads and unloads both CNC machines, eliminating repetitive manual handling at the station. The customer expanded production capacity without adding labor, and the cell meets its sub-60-second cycle time requirement at over 98% system efficiency. Freed from load and unload duties, operators can focus on higher-value work while 3D vision keeps randomly stacked parts flowing.