Molded shells leave the mold machine with thin fins and flash along their parting lines, and every one has to be removed before the shell moves to the next process. Done by hand, deburring is repetitive, dusty work, the result depends on the person doing it, and a slip can crack a shell. The plant needed a compact, repeatable machine that removes fins the same way on every shell, keeps team members away from the dust, and can be duplicated across many lines.
Key Requirements
Remove fins and flash from molded shells consistently
Hold each shell securely without damaging it
Interface with the customer’s cobot for automatic load and unload
One-touch start for manual loading
Light-curtain guarded opening
Collect debris away from the part
Compact, mobile, repeatable design for many lines
The ICR Solution
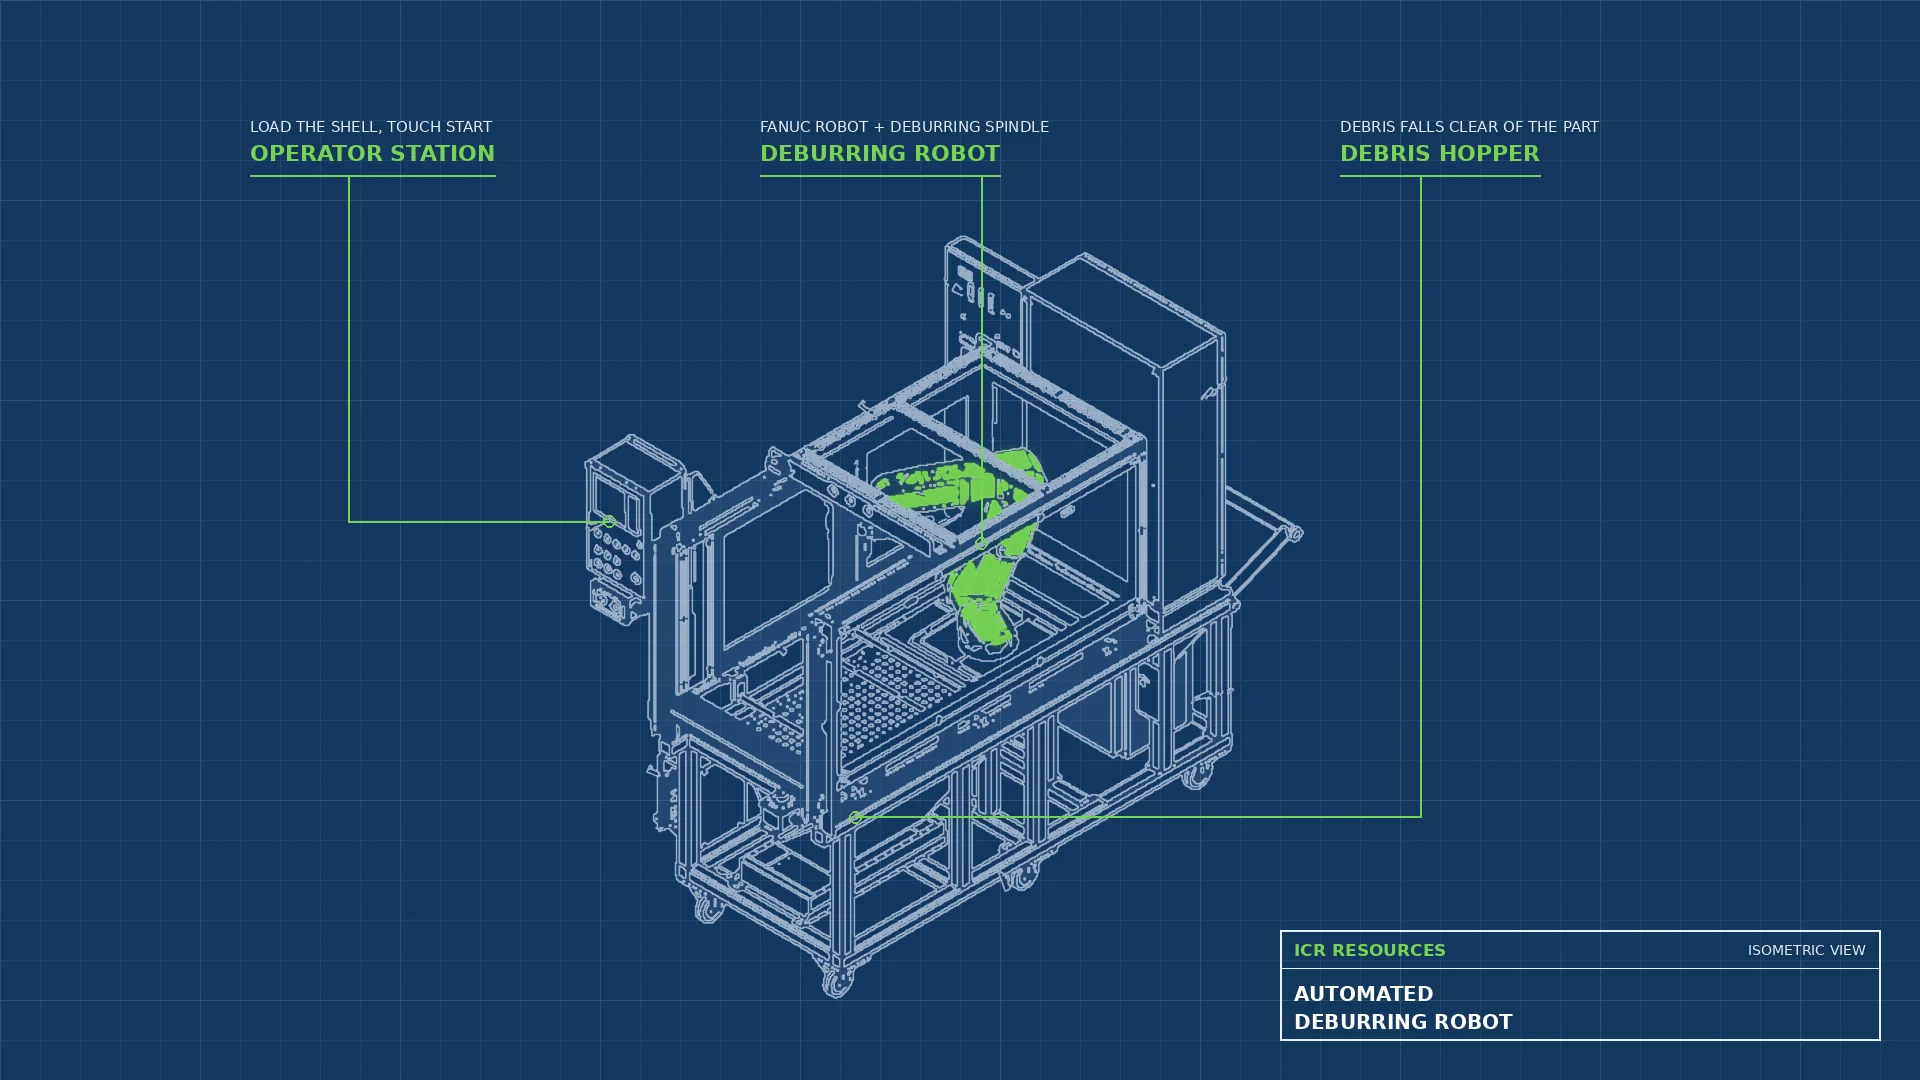
ICR designed a self-contained deburring robot cell around a FANUC LR Mate robot. The robot carries a brushless motor-driven spindle on a spring-floated compliant mount, so the tool follows the molded shell and takes off the fin without gouging it. A shell is placed on the jig, sensors confirm it is seated, five pneumatic clamp circuits hold it, and the program runs. In a cooperative effort with the customer, ICR built in a cobot interface so the customer’s own collaborative robot loads and unloads the cell, with one-touch manual start kept as a backup. Debris falls through a perforated table into a hopper below. Keyence light curtains guard the opening, and the panels and robot controller ride on one mobile base. The design is standardized, and ICR has built 41.
Equipment & Technology
FANUC LR Mate 200iD robot with R-30iB controller
Oriental Motor brushless spindle motor
Compliant floating spindle mount
Pneumatic shell clamps (5 circuits)
Keyence safety light curtains
PLC with touchscreen HMI
Cobot interface panel
Perforated work table and debris hopper
Mobile base with onboard panels
Scope of Work
Mechanical Design
Controls Design
Fabrication and Assembly
Panel Build
Robot Programming
PLC/HMI Programming
Cobot Interface
Installation
Commissioning
Results
With 41 built, the deburring robot is a proven, repeatable ICR design. Every molded shell gets the same fin removal, and working with the customer’s cobot team, load and unload are fully automatic, keeping team members away from the dust and off the hand tools. Because each cell is self-contained on a mobile base with common components, new units deploy quickly and share spare parts across the plant.